Portrait of Jie Chen in front of the Golden Gate Bridge Portrait of Jie Chen by the sea

Jie Chen

Ph.D. student, National University of Singapore

MARMot Lab, advised by Asst. Prof. Guillaume Sartoretti

A*STAR IAIC, AGS scholar, advised by Dr. Wei-Yun Yau

Generalizable robot learning, world models, and foundation models for embodied agents.

About

I am currently a Ph.D. student at the National University of Singapore (NUS). I research in the Multi-Agent Robotic Motion (MARMot) Laboratory advised by Asst. Prof. Guillaume Sartoretti. I’m also an AGS scholar co-supervised by Dr. Wei-Yun Yau at the A*STAR Institute of Advanced Intelligence and Computing (IAIC). Before this, I obtained my Master of Science degree from NUS and a B.Eng degree in Mechatronics from Chongqing University.

My research interests span generalizable robot learning, world models, and foundation models for embodied agents.

Outside the lab

I work out (bench press 100 kg, 25 pull-ups, strict press 70 kg), play the drums (noob level), and listen to a lot of Midwest emo (Chinese/American/Japanese Football, toe, …). When I game, it's usually Overwatch, Minecraft, or The Legend of Zelda.

I also love birds, owls most of all.

Watch the birds
Burrowing owlNational Aviary, Pittsburgh
Toco toucanNational Aviary, Pittsburgh
African penguinsNational Aviary, Pittsburgh
Victoria crowned pigeonBird Paradise, Singapore
TuracoBird Paradise, Singapore
EgretsTaihu Lake, Wuxi
GullsFisherman's Wharf, San Francisco
Black swans and cygnetsChongqing University
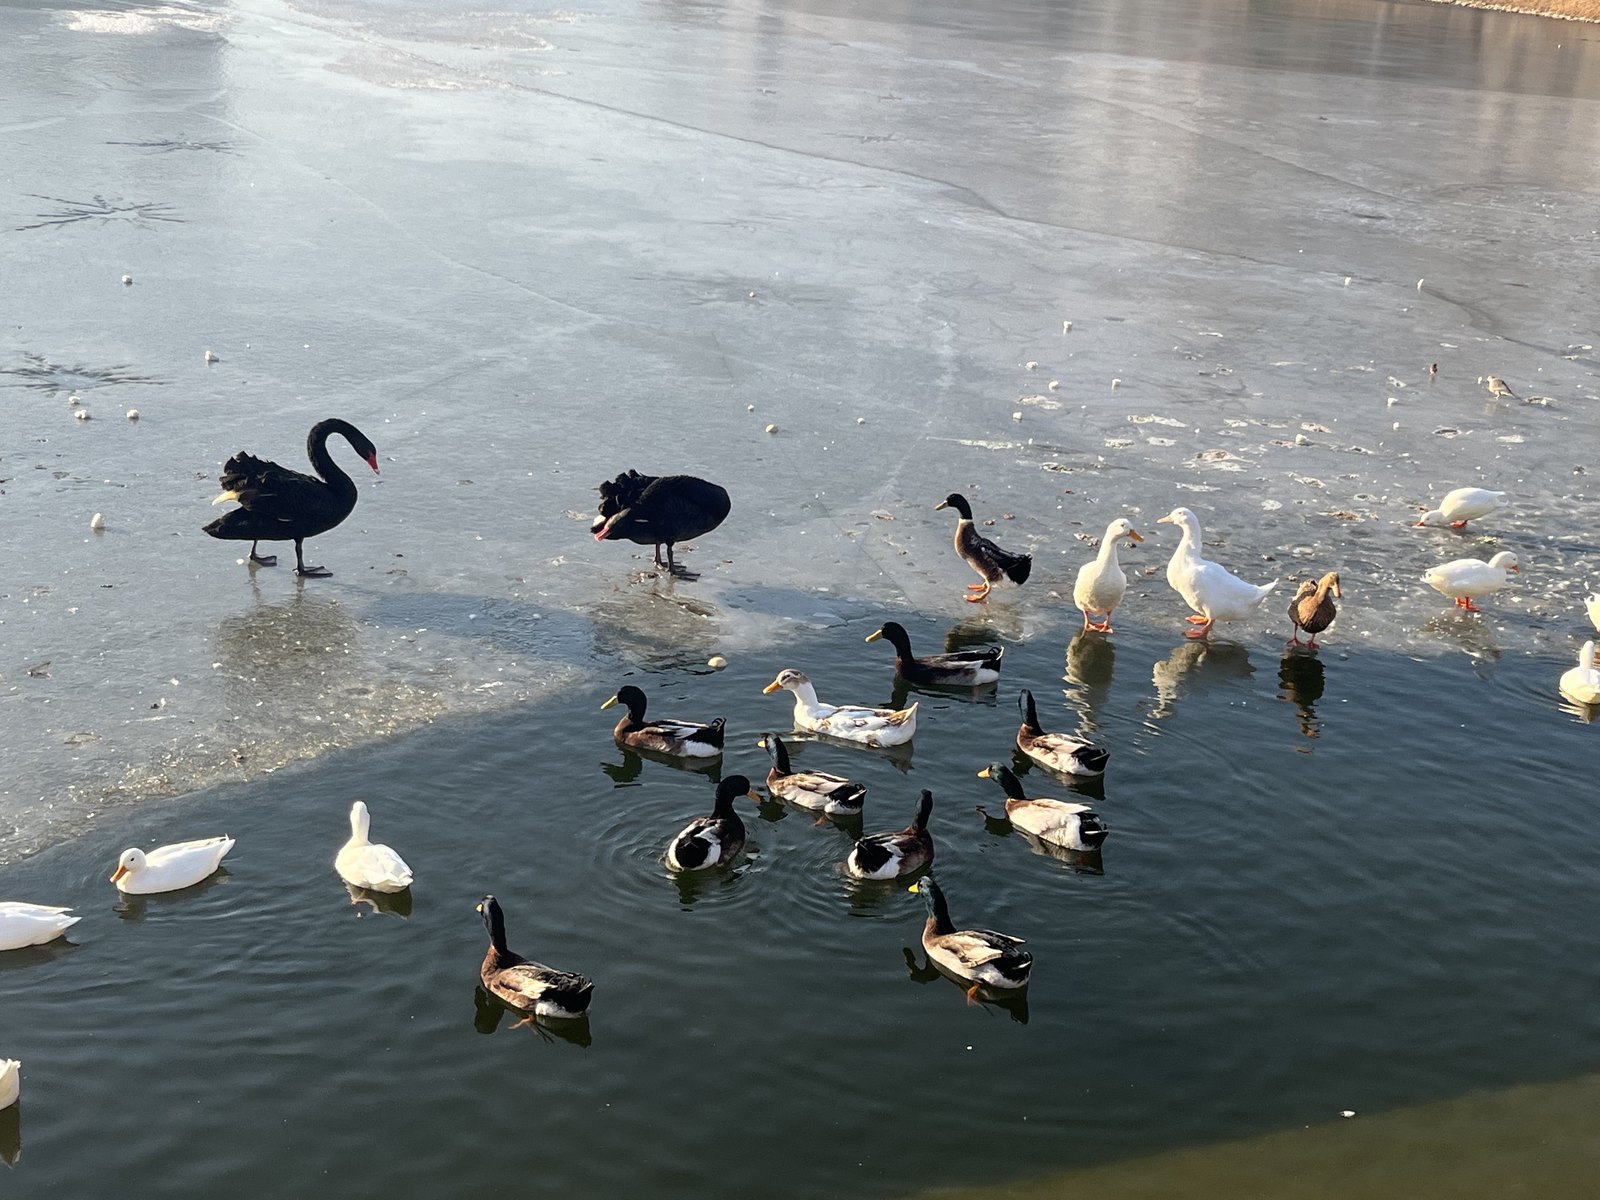
Black swans and ducks at Tianjin University
Black swans and ducksTianjin University

9 sightings from 6 places

Publications

  1. MiniWAM: Learning Compact Future Targets for Efficient World-Action Modeling

    Jie Chen, Ruofei Bai, Yuxin Cai, Yifeng Zhang, Chengyang He, Jun Li, Wei-Yun Yau, and Guillaume Sartoretti

    arXiv 2026arXiv preprint arXiv:2610.12194

    Project pagearXiv

  2. Robots as Tokens: Unified Diffusion Transformer for Coordinated Multi-Robot Trajectory Generation

    Ruofei Bai, Jie Chen, Yuxin Cai, Jun Li, Wei-Yun Yau, and Lihua Xie

    CoRL 20262026 Conference on Robot Learning (CoRL)

    Project pagearXiv

  3. ImagiNav: Scalable Embodied Navigation Via Generative Visual Prediction and Inverse Dynamics

    Jie Chen, Yuxin Cai, Yizhuo Wang, Ruofei Bai, Yuhong Cao, Jun Li, Wei-Yun Yau, and Guillaume Sartoretti

    IROS 20262026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)

    Project pagearXiv

  4. Beyond Imitation: Reinforcement Learning Fine-Tuning for Adaptive Diffusion Navigation Policies

    Junhe Sheng, Ruofei Bai, Kuan Xu, Ruimeng Liu, Jie Chen, Shenghai Yuan, Wei-Yun Yau, and Lihua Xie

    IROS 20262026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)

    arXiv

  5. FISS+: Efficient and Focused Trajectory Generation and Refinement Using Fast Iterative Search and Sampling Strategy

    Shuo Sun, Jie Chen, Jiawei Sun, Chengran Yuan, Yuanchen Li, Tangyike Zhang, and Marcelo H. Ang Jr.

    IROS 20232023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)

    PaperCode

Research taste is the ability to navigate the Strait of Messina, steering between Scylla the trivial and Charybdis the impossible.

Alien monster icon by OpenMoji, CC BY-SA 4.0